Ardalan Aryashad
Ph.D. Student, Aerospace & Mechanical Engineering · USC
M.S. Student, Department of Computer Science · USC
I’m a third-year AME Ph.D. student at USC, advised by Prof. Yan Jin. I have recently started an M.S. in Computer Science.
At the IMPACT Lab, I am currently working on vision-language-action (VLA) models and their applications in robotic task planning and manipulation, and agentic AI approaches for MBSE modeler tasks.
news
| May 18, 2026 | SEMAA accepted to ASME IDETC-CIE 2026. |
|---|---|
| May 13, 2026 | FSAE 2026: USC Racing won Autocross (1st), placed 7th overall, and reached the Design Finals. |
| Mar 06, 2026 | Filters to VLMs accepted as an Oral and presented at WACV 2026, Tucson, AZ (Mar 6–10). |
| Aug 25, 2025 | Started my MS in Computer Science at USC. |
| Aug 17, 2025 | VLAG presented at ASME IDETC/CIE 2025, Anaheim, CA (Aug 17–20). |
| May 19, 2025 | VLAG accepted to ASME IDETC/CIE 2025. |
| May 14, 2025 | FSAE 2025 : USC Racing’s first-ever podium — 3rd in Autocross and a Design Finals appearance. |
| Aug 21, 2023 | Started my PhD in Mechanical Engineering at USC. |
publications
- WACV 2026
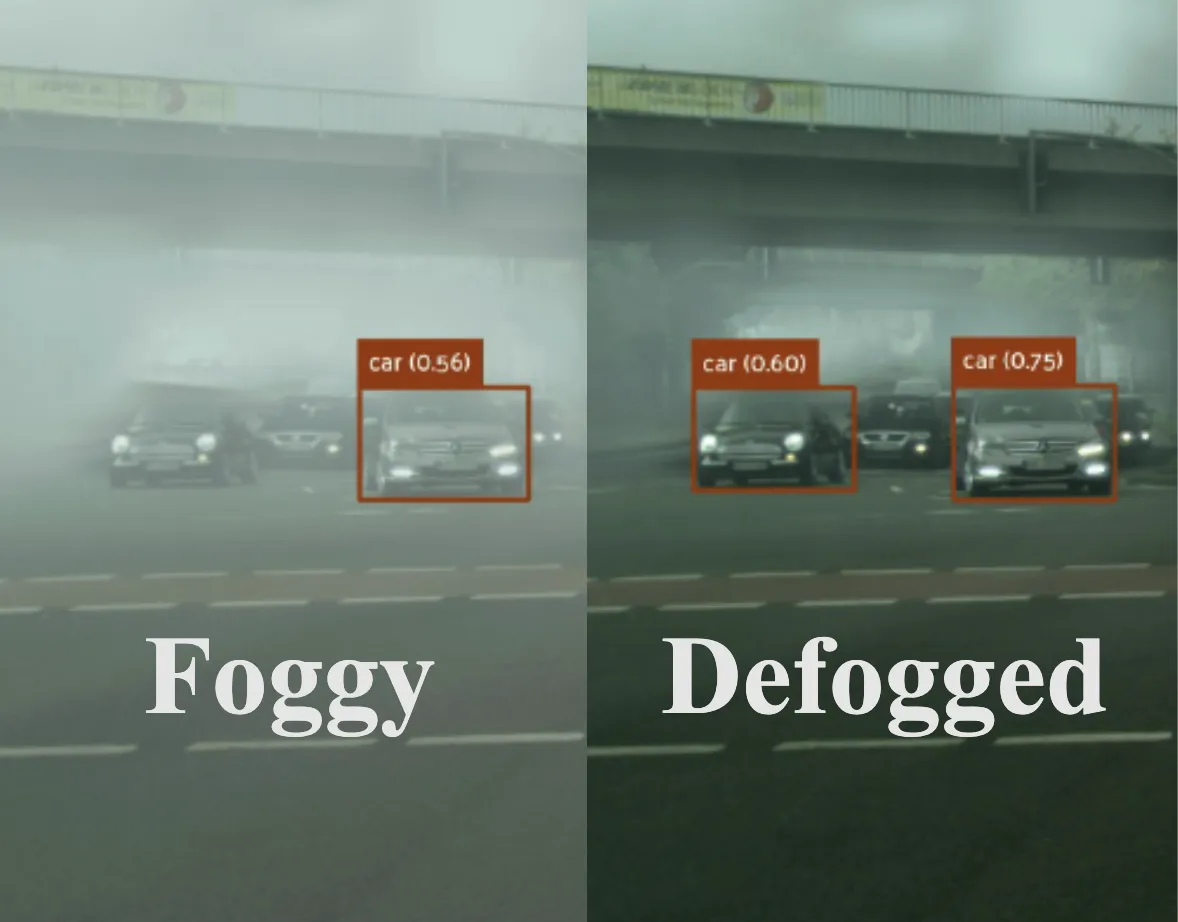 In IEEE/CVF Winter Conference on Applications of Computer Vision (WACV) Workshops, 2026
- IDETC 2025
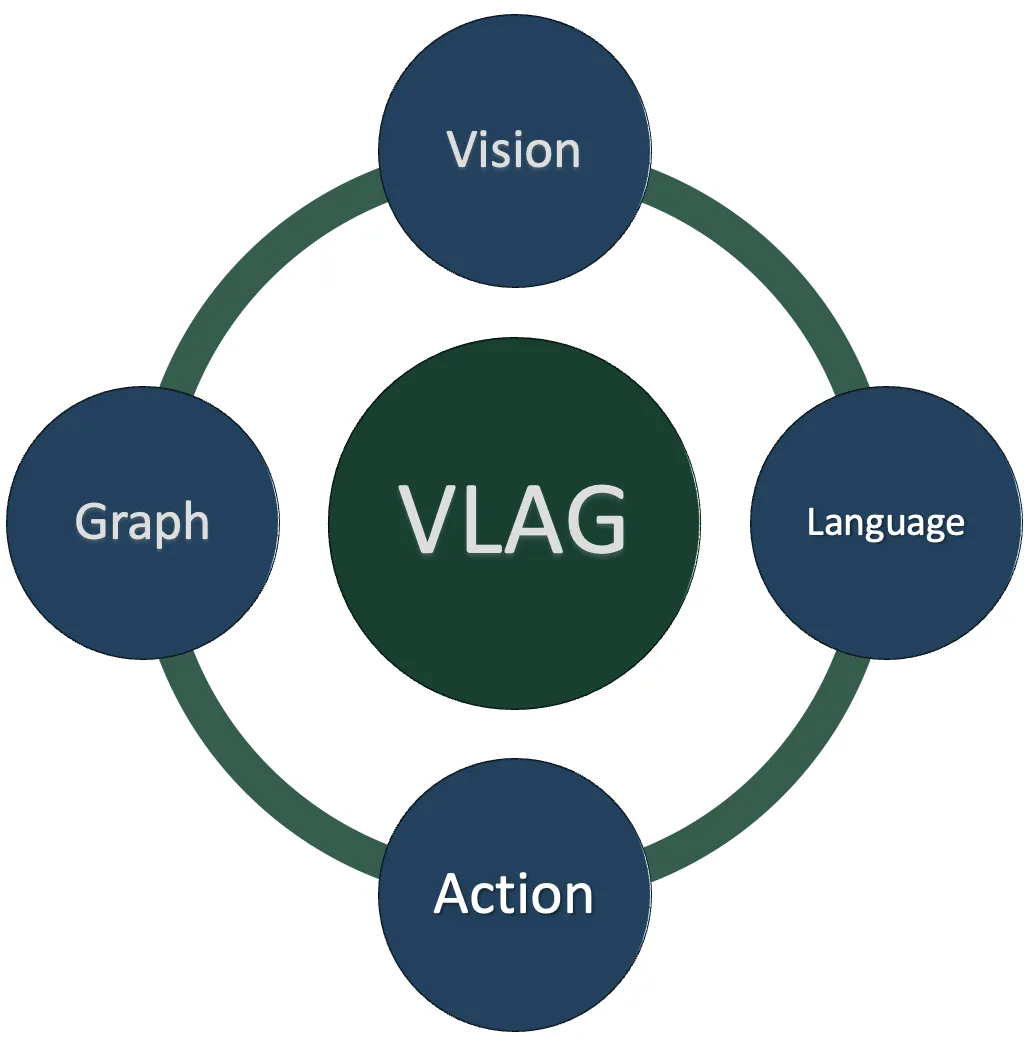 In ASME International Design Engineering Technical Conferences (IDETC/CIE), 2025
projects
Fall 2024 – Present 
Two years with USC Racing, split between hands-on suspension work and building tools that made the car’s data useful at the track.
2025–Ongoing 
SEMAA brings conversational AI into everyday systems-engineering work, from editing diagrams to working with private engineering data.
Spring 2026 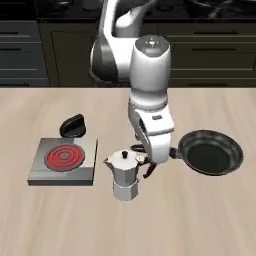
An experiment in merging task-specific robot policies that produced a clear negative result: averaging their weights did not preserve the skills.
Fall 2024 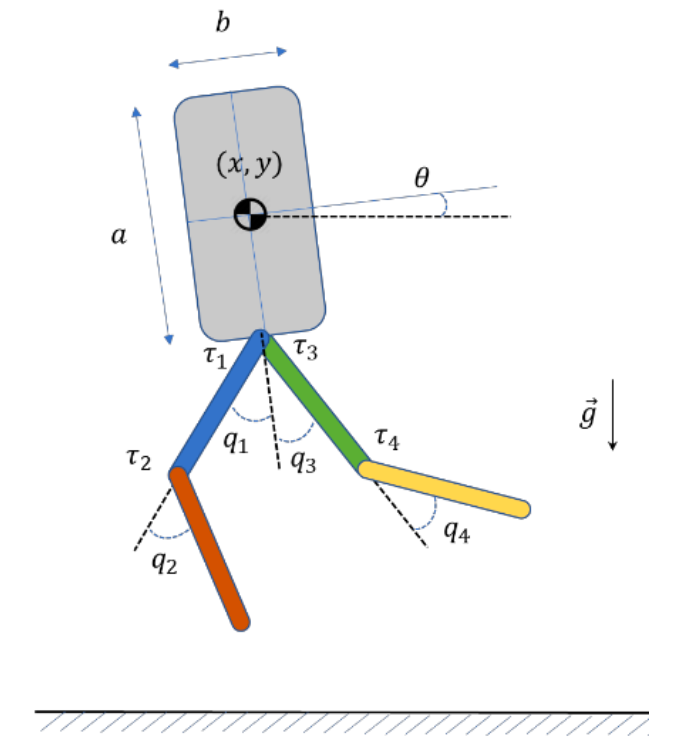
We used a single model-predictive controller to make a simulated biped stand, walk, run 10 meters, and climb stairs.
Fall 2023 
A course project that took messy automotive sensor data from preprocessing and model comparison to a working maintenance app.